Industrial Robot
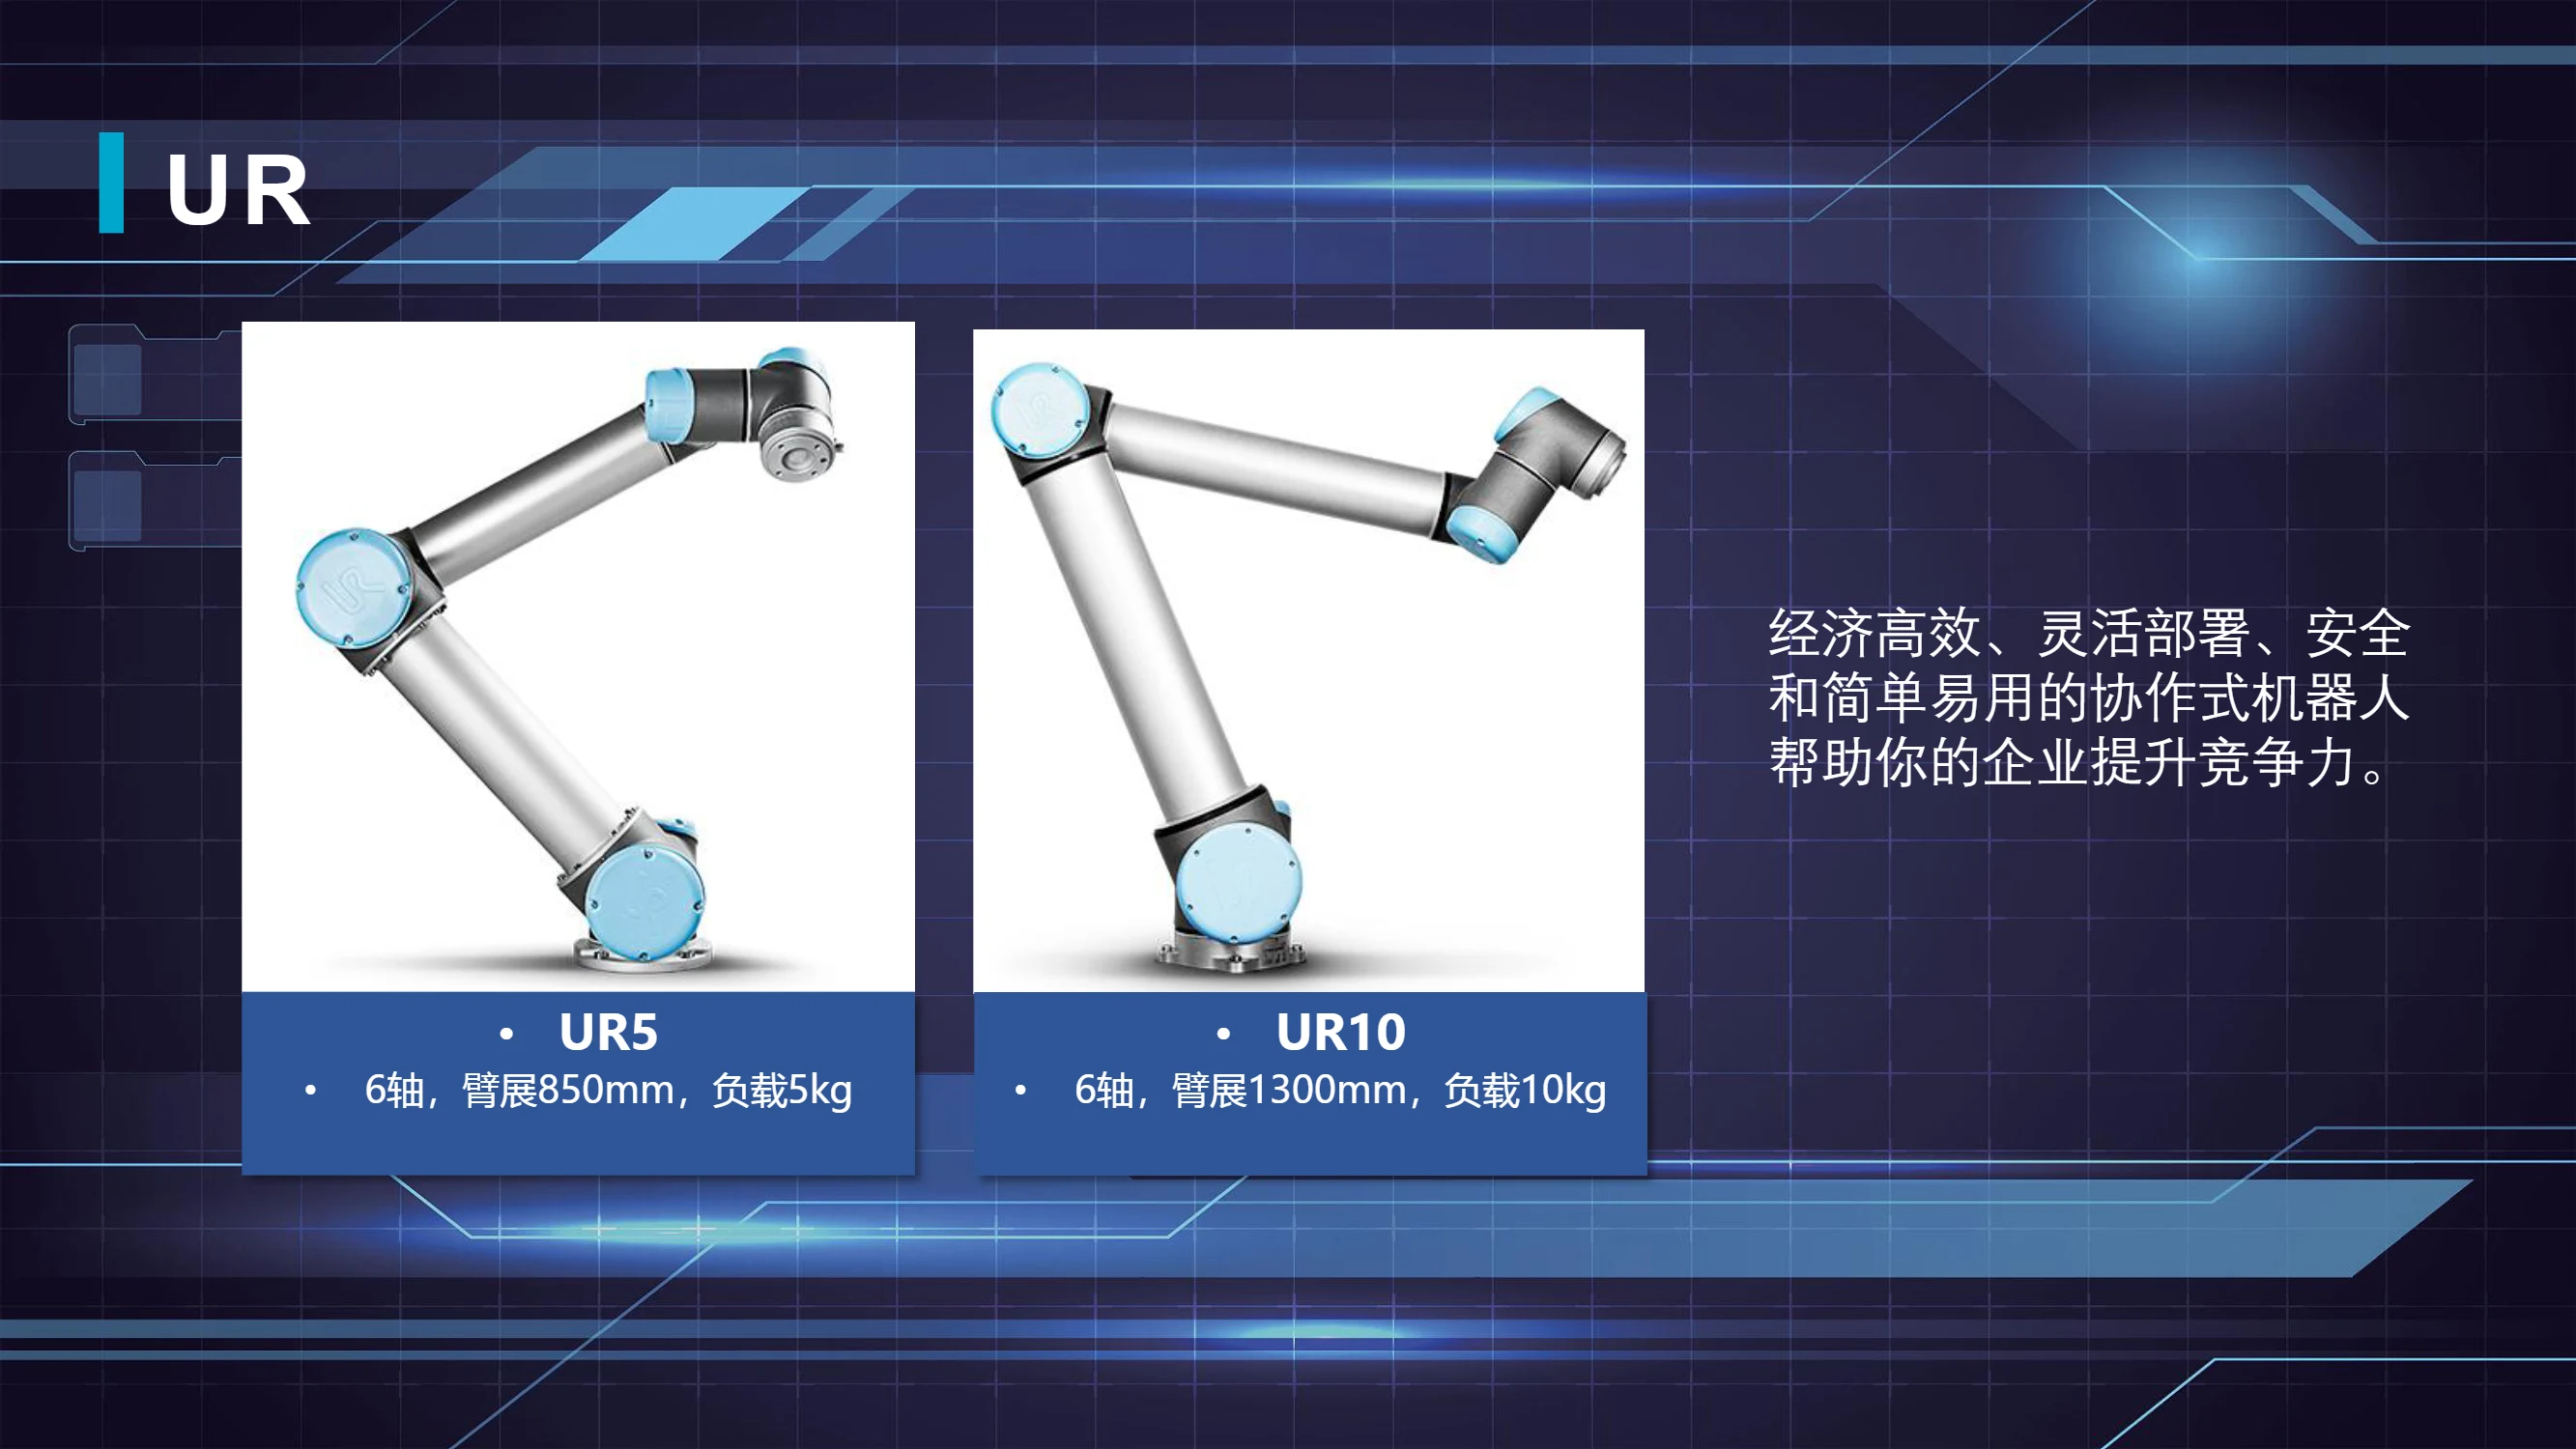
UR Series Collaborative Robots
The UR Series is a range of six-axis collaborative robots featuring lightweight articulated arms, designed for human-robot collaboration. According to the catalog, the series includes two main models: the UR5, with 6 axes, an 850 mm reach, and a 5 kg payload; and the UR10, with 6 axes, an approximately 1,300 mm reach, and a 10 kg payload (shown as JR10 in the source, likely due to an OCR error). Collaborative robots typically use joint torque control and can operate in the same workspace as people, generally without traditional safety fencing. They are commonly used to automate tasks such as machine tending, loading and unloading, assembly, material handling, palletizing, and inspection. Reach and payload are the key parameters for model selection; controller configuration, tool flange, and mounting accessory requirements should also be considered. The catalog does not provide a complete model-numbering scheme for this series.
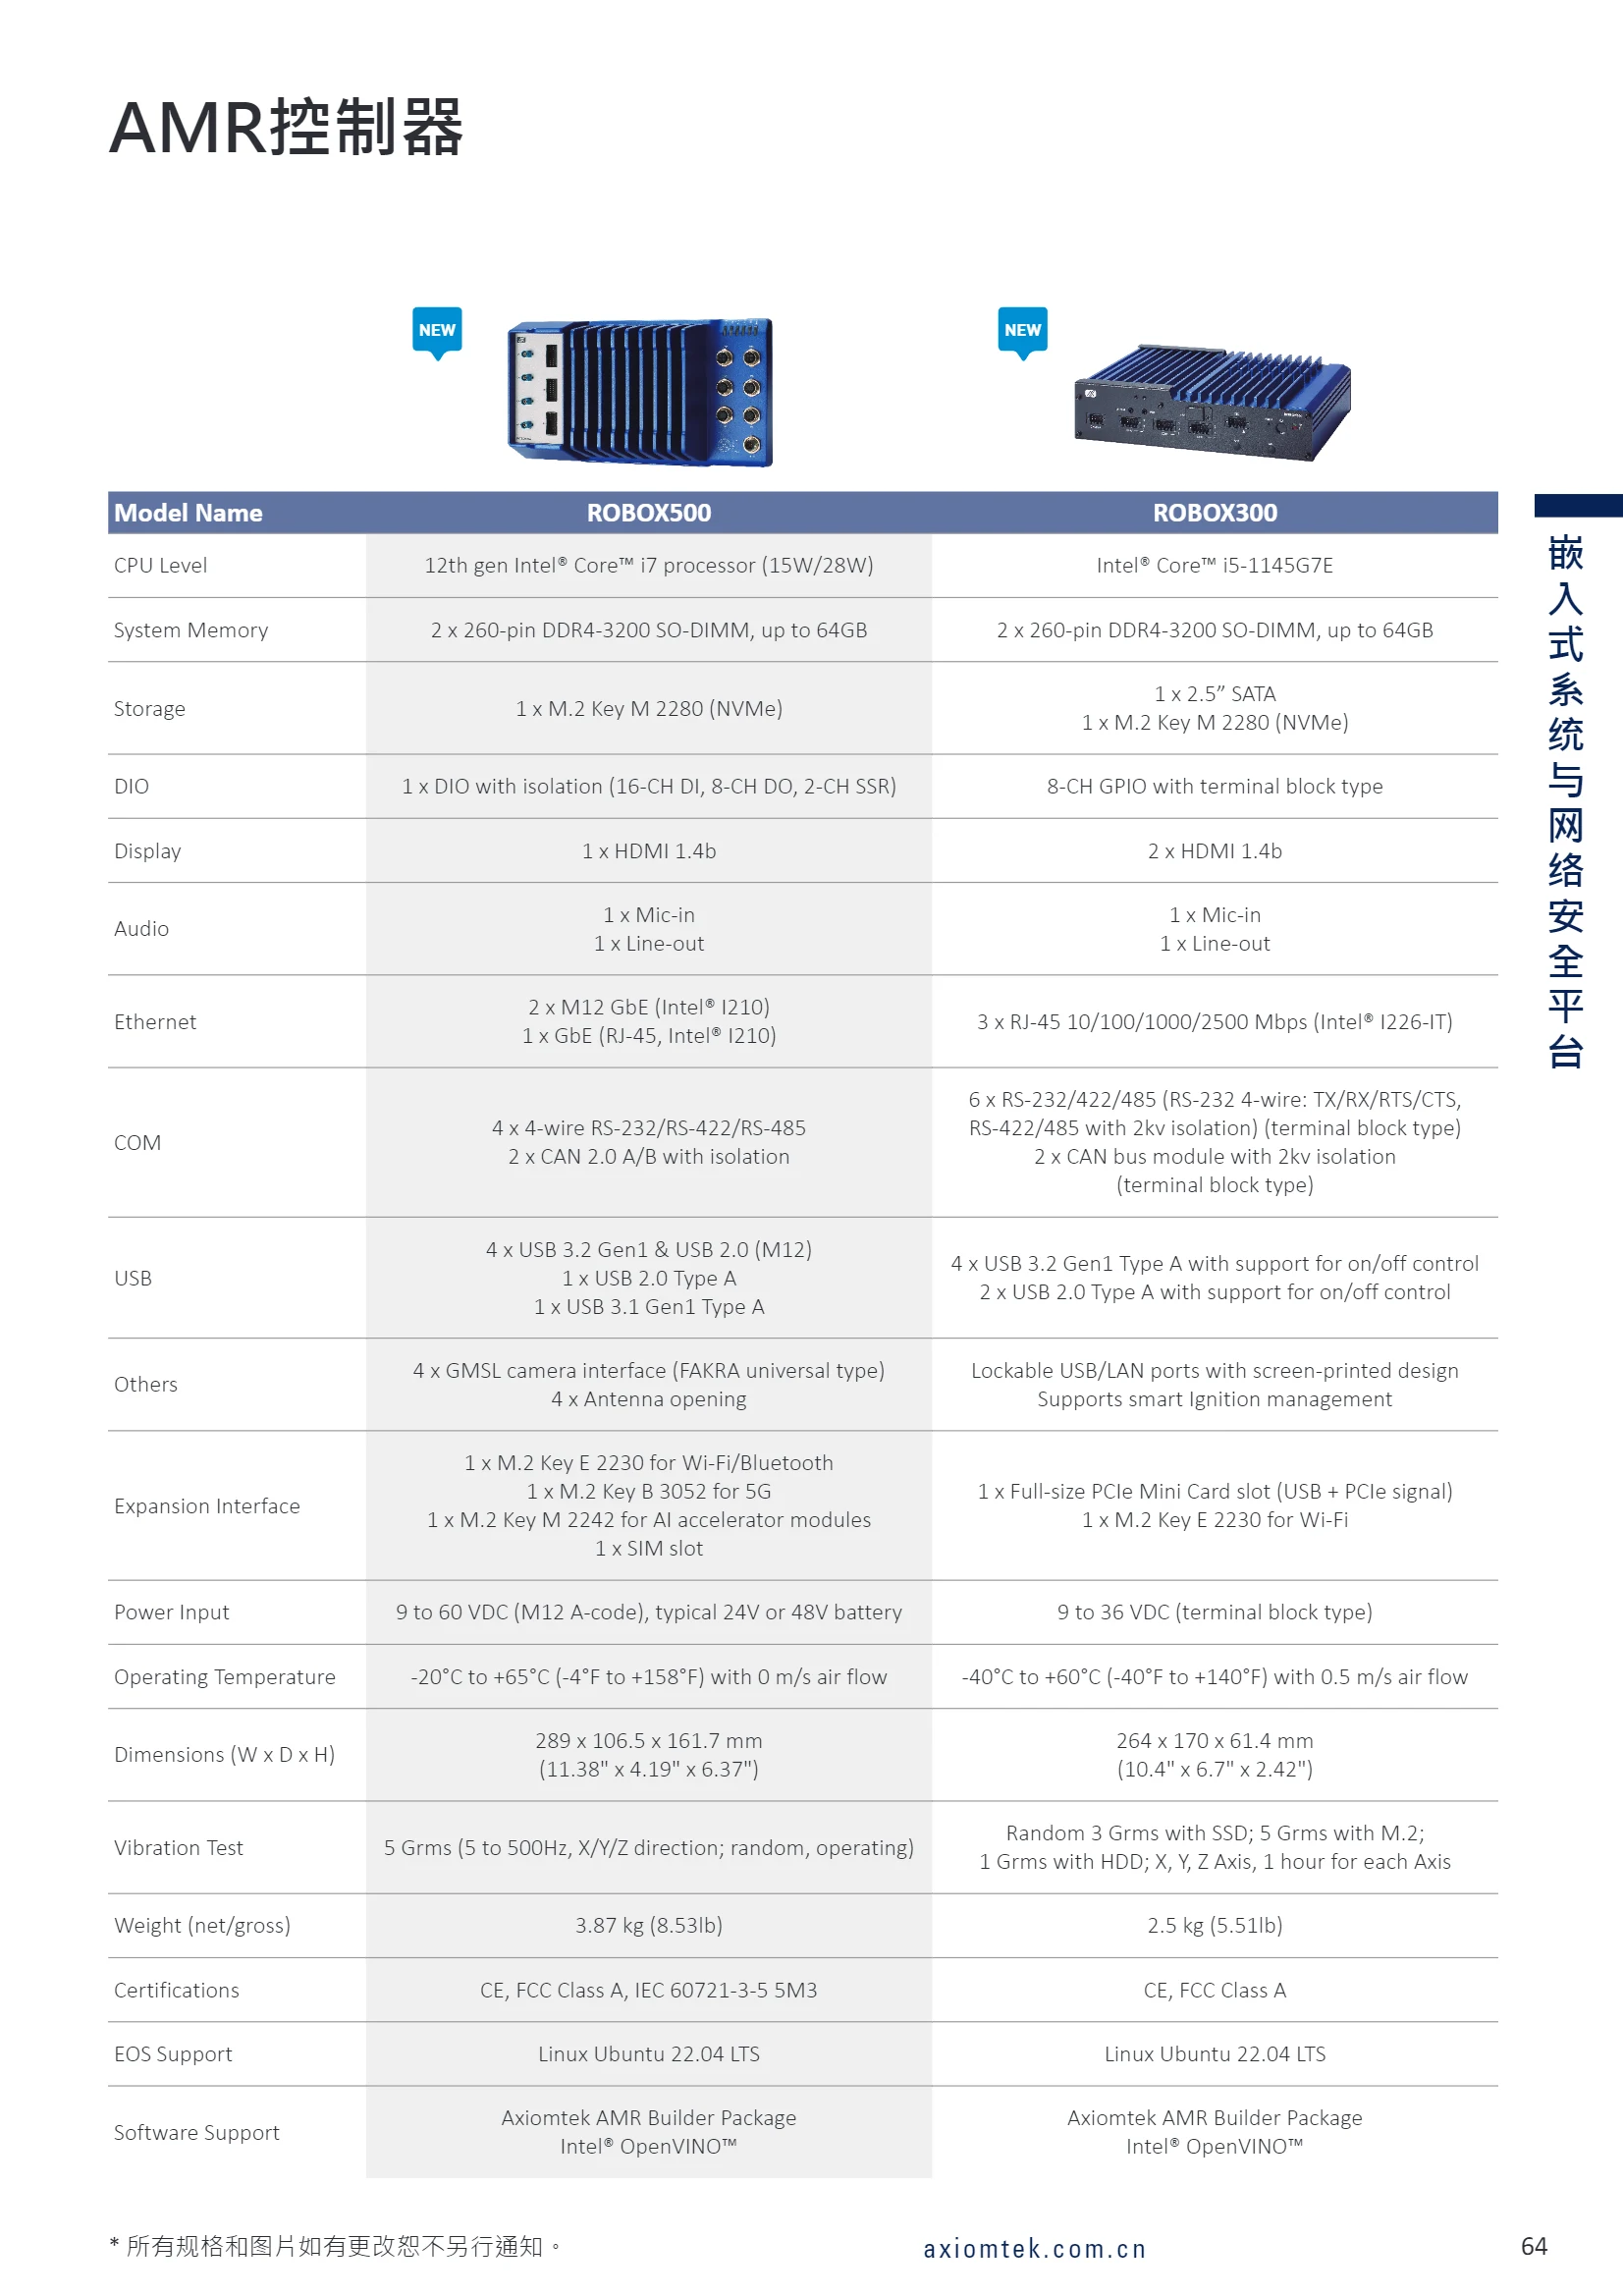
ROBOX Series Autonomous Mobile Robot (AMR) Controllers
The ROBOX Series comprises embedded controllers for autonomous mobile robots (AMRs/AGVs), with two main models: ROBOX500 and ROBOX300. The ROBOX500 features a 12th Gen Intel Core i7 processor (15W/28W), while the ROBOX300 is powered by an Intel Core i5-1145G7E. Both support two DDR4-3200 SO-DIMM memory modules, up to 64 GB of memory, and M.2 NVMe storage. The series offers extensive I/O, including multiple Gigabit Ethernet ports, isolated serial ports, a CAN 2.0 bus, isolated DIO/GPIO, USB ports, and HDMI display output. The ROBOX500 also provides four GMSL camera interfaces, making it ideal for onboard visual perception and sensor fusion. Power input supports a wide range of 9–60 VDC or 9–36 VDC. Operating temperatures range from -40°C to +65°C, and the system withstands 3–5 Grms of random vibration. It is certified to CE and FCC Class A
High-Precision Miniature Electric Parallel Gripper
The high-precision miniature electric parallel gripper is a compact electric end effector that saves space in equipment designs and supports mounting on multiple faces to suit a variety of gripping tasks. With opening and closing times as fast as 0.3s/0.3s, it meets production line requirements for fast, stable gripping. It supports I/O control and multiple communication options, including RS485, CAN, and EtherCAT, for easy integration with different control systems. This precise and reliable electromechanical gripping solution is suited to high-speed handling of small parts in 3C electronics, semiconductor manufacturing, precision assembly, and other applications.
High-Precision Miniature Rotary Gripper
The high-precision miniature rotary gripper is an electric end effector that combines gripping and rotation for precise handling at any angle. Its standardized modular design integrates drive and control functions, with a built-in servo drive and minimal communication latency. The result is a precise, reliable electromechanical solution with high reliability and consistent quality. It is suited to automated applications in 3C electronics, precision assembly, and small-part handling that require parts to be flipped or rotated to a specific angle after gripping. Optional I/O control, RS485, CAN, and EtherCAT interfaces make it easy to integrate with production line control systems.
High-Precision Electric Adaptive Gripper
The high-precision electric adaptive gripper uses a biomimetic joint design and intelligent adaptive algorithms to automatically adjust its grip to the shape of the object, securely conforming to irregularly shaped, fragile or slippery workpieces. This electric end effector is suited to flexible gripping and mixed-model production lines. It can replace conventional pneumatic grippers for more flexible and reliable gripping. The current catalog page does not specify stroke, gripping force, repeatability, communication interfaces or model coding rules; these should be confirmed against the operating requirements when selecting a model.
Long-Stroke, High-Force Gripper
The long-stroke, high-force gripper is a servo-electric end effector that combines a long stroke, high load capacity and micron-level positioning. Designed for gripping heavy and large workpieces in industrial automation, it can replace conventional pneumatic grippers to provide versatile, precise and reliable handling. Its integrated drive and control design features a built-in servo drive for low communication latency and fast response. It supports I/O control, RS485, CAN and EtherCAT, and its opening stroke and gripping force can be adjusted to suit the size and shape of the workpiece. It is suitable for handling, loading and unloading, assembly, palletizing and other operations. Its compact design and multiple mounting surfaces make it easy to integrate into a wide range of robots and automated production lines, delivering reliable gripping with consistent quality.
Anthropomorphic Five-Finger Dexterous Hand
The anthropomorphic five-finger dexterous hand is a highly integrated actuator designed for robotic end-effector applications. Using LENFOR drive, control and transmission technology, it integrates the drive, transmission and control modules within the palm. With high driving force, precise control and rapid response, it performs human-like hand movements such as grasping, pinching and twisting. Its modular design allows individual fingers and joint modules to be disassembled independently for quick replacement and routine maintenance, reducing operating and repair costs. This product is available for development and customization, with the number of degrees of freedom, dimensions, communication interfaces and control methods tailored to the application. Related products in the same series, including the ZR axis, are still in development. Applications include collaborative robots, humanoid robots, research and education, and operations in hazardous environments.
LF-MEGF Series High-Precision Miniature Electric Parallel Grippers
The LF-MEGF series comprises high-precision miniature electric parallel grippers with integrated controllers. Their compact design allows mounting on any face except the cable outlet end, making them suitable for space-constrained gripping stations requiring flexible mounting. Opening and closing times are as fast as 0.3 s/0.3 s. The series offers strokes of 15~70 mm, maximum gripping forces of 3~100 N (adjustable in four steps via I/O), maximum recommended loads of 0.06~1 kg, and position repeatability of ±0.02 mm. It supports three absolute positions triggered by I/O combinations, as well as empty-grip and drop detection and gripping feedback. Control is via I/O, with I/O and Modbus RTU (RS485) communication supported. Rated voltage is DC24V±10%, no-load current is 0.1~0.2 A, peak current is 0.3~0.5 A, protection rating is IP40, and operating noise is ≤50 dB. The operating environment is 0~55℃ and below 85% RH. Typical tasks include picking, gripping, handling, assembly, and loading and unloading in industries such as 3C, new energy, semiconductors, and medical technology.
MEGF Series High-Precision Miniature Electric Parallel Grippers
The LF-LENFOR MEGF series high-precision miniature electric parallel grippers feature an electric drive and parallel gripping mechanism for handling miniature parts, precision assembly, and loading and unloading for inspection. The body is 23 mm wide, with an example stroke of 6 mm. Gripping force is selected using codes such as 015/030/050/060. Cable outlet options include B-Bottom and S, while communication options include PWM, TTL, Modbus RTU(RS485), EtherCAT, I/O(NPN/PNP), and CAN. Mounting options include default front end cover mounting, rear end cover mounting, and mounting through fixed holes on a flat surface. A holding brake is optional. Compatible 12-pin connectors are HC-HY-12Y/HC-HY-12A; the 26AWG cable assignments include OUT0~OUT2, IN0~IN2, 485±, 0V, and 24V.
LF-MERG Series High-Precision Miniature Rotary Grippers
The LF-MERG series high-precision miniature rotary grippers use an integrated remote-control design, combining servo drive, gripping and rotation in a compact body to provide a high-precision mechatronic rotary gripping solution with low communication latency. They support continuous rotation, adjustable rotational torque, self-locking on power loss and real-time position feedback. Rotational repeatability is up to ±0.05°, and positional repeatability is ±0.02mm. The series is available in 34mm and 44mm body widths, with total strokes of 15mm/32mm, gripping forces of 35N/100N, rated torque of 0.2N·m, peak torque of 0.5N·m/1N·m, maximum recommended payloads of 0.6kg/1.5kg, and maximum rotation speeds of 2160°/s and 1350°/s. Electrical specifications include a rated voltage of DC24V±10%, rated current of 0.3A/0.5A, peak current of 1A/1.5A, and an IP40 protection rating. The recommended operating environment is 0~55℃ and below 85%RH. Modbus RTU(RS485) communication is standard, with optional PWM, TTL, EtherCAT, I/O(NPN), I/O
LF-LEAGF Series High-Precision Electric Adaptive Grippers
LF-LEAGF Series high-precision electric adaptive grippers use a biomimetic joint design and an intelligent adaptive algorithm to automatically adjust their gripping posture to the shape of the object, ensuring a stable grip on irregularly shaped, fragile, or slippery workpieces. They offer a gripping force of 15~200 N, a total stroke of 65~95 mm, position repeatability of ±0.03 mm, and a maximum recommended payload of 0.65~1.2 kg. An integrated controller is built in, with Modbus RTU (RS485) and Digital I/O as standard and optional TCP/IP, USB2.0, CAN2.0A, PROFINET, and EtherCAT communication. Rated IP40, they are suitable for gripping, arranging, and loading and unloading applications in the 3C, semiconductor, food, and medical industries.
LF-LEAGF Series High-Precision Electric Adaptive Grippers
The LF-LEAGF series from Lanfang (LF) comprises high-precision, servo-driven electric adaptive grippers that accommodate workpieces of different sizes and shapes, with a wide range of strokes and support forces. Model numbers follow a standard sequence: company code LF, product series LEAGF, width, stroke, support force, cable exit position, communication method, mounting method, and brake option. Widths range from approximately 0-99mm, strokes from 1-9999mm, and support forces from 1-9999N. Communication options include Modbus RTU(RS485), EtherCAT, CAN, TTL, PWM, and NPN/PNP digital I/O. The cable can exit from the side or bottom. Mounting options include the default front end-cap mounting and flat mounting holes, with brake-equipped models also available. A 10P-M16 metal circular connector is supplied, with a female connector on the product and a male mating connector, along with wiring connections defined for 24V/0V/485±/IN/OUT and other signals. Applications include robot end effectors, automated assembly, and flexible loading and unloading.
LF-LEGF Series Long-Stroke, High-Force Electric Grippers
The LF-LEGF series long-stroke, high-force electric grippers are servo-electric end effectors combining extra-long stroke, high payload capacity, and micron-level positioning. They replace conventional pneumatic grippers with a versatile, precise, and reliable solution. All models feature an integrated controller and support I/O, Modbus RTU (RS485), and EtherCAT communication. Four gripping force settings are adjustable via I/O, and three absolute positioning settings can be triggered by I/O combinations. Position repeatability is ±0.05mm, maximum opening and closing speed is 30mm/s, and drop detection and power-off self-locking are supported. Three sizes offer strokes of 80/140/240mm, maximum gripping forces of 500/1000/2000N, and maximum recommended payloads of 8/16/30kg. Rated voltage is DC24V±10%, no-load current is 2A, peak current is 5~6A, and unit weight is 5~6.5kg. The grippers are rated IP40, with operating noise ≤50dB and an operating environment of 0~55℃ and below 85%RH. They are bottom-mounted. Typical tasks include picking, gripping, handling, and machine loading and unloading. They are widely used for large-scale applications in automotive components, semiconductors, food, lithium batteries, and other industries.
LF-LEGF Series Long-Stroke, High-Force Grippers
The LF-LEGF series is LF-LENFOR's line of long-stroke, high-force electric grippers. Featuring parallel opening and closing, these grippers offer strokes of 0-99 mm and gripping forces of 001-999 N, accommodating both small workpieces and medium to large loads. Three M4 threaded mounting holes spaced 10 mm apart are arranged symmetrically on both sides of the body. Mounting options include the default front end cover, rear end cover, side, and mounting holes on a flat surface, allowing flexible integration into automated production lines, robot end effectors, and inspection equipment. Cables can exit from the bottom or side. Communication options include PWM, TTL, Modbus RTU(RS485), EtherCAT, and NPN/PNP digital I/O. A version with a brake is also available to maintain the grip during power loss. Products are supplied with customer-specific codes. The model code follows this sequence: company name-product series-stroke-gripping force-cable exit position-communication method-brake function-mounting method.
LF-MEGF23 Series High-Precision Miniature Electric Parallel Grippers
The LF-MEGF23 series high-precision miniature electric parallel gripper features a built-in integrated controller and a compact design. Its body measures 23.5×38×88.7mm and weighs approximately 0.26kg. It can be mounted on any face except the cable outlet end, allowing flexible installation in confined spaces. With a 6mm stroke and minimum opening and closing times of 0.3s each, it provides fast, stable gripping on production lines. Maximum gripping force is available in four options: 15N, 30N, 50N, and 60N, with four-level adjustment via I/O. The maximum recommended payload is 0.3~1.2kg, positioning repeatability is ±0.02mm, and three absolute positioning settings of 2mm/4mm/6mm are supported, triggered by I/O combinations. Control is via I/O(NPN) with 2 inputs and 2 outputs. Communication supports I/O and Modbus RTU (RS485); the catalog also lists support for CAN and EtherCAT. Rated voltage is DC24V±10%, no-load current is 0.1A, peak current is 0.3A, protection rating is IP40, and operating noise is ≤50dB. The operating environment is 0~55℃ and below 85%RH. The gripper also provides precise force control
LF-MEGF29 Series High-Precision Miniature Electric Parallel Grippers
The LF-MEGF29 series consists of high-precision miniature electric parallel grippers with an electric drive, parallel jaw movement, and a compact body. They are suitable for handling small parts, electronic assembly, inspection, and positioning. The grippers support digital inputs and outputs and RS485 communication control. Wiring assignments include OUT0~OUT2, IN0~IN2, 485+, 485-, 0V, and 24V. The current range includes 050 and 100 specifications. The product-side connector is HC-HY-12Y(HCTL), and the socket-side connector is HC-HY-12A(HCTL). Both are 12-pin connectors for easy integration with controllers and host systems.
LF-RH1X Series Five-Finger Dexterous Hand
The LF-RH1X series dexterous hand features a humanoid five-finger design and is available in 6-degree-of-freedom and 15-degree-of-freedom configurations, with right- and left-hand models (LF-RH1X-1R is the right hand; LF-RH1X-1L is the left hand). It supports RS485/CAN control interfaces and operates on a DC24V±20% power supply. Maximum current is 2A for the 6-degree-of-freedom configuration and 3.6A for the 15-degree-of-freedom configuration, with a positioning accuracy of ±200um. Maximum grip force is 10N/15N for the thumb and 8N/15N for the four fingers. The thumb's lateral rotation range exceeds 65°, with a lateral swing speed of 235°/s and a bending speed of 150°/s. The four-finger bending speed is 570°/s. Applications include nuclear waste sorting, in-home elderly assistance, coffee latte art, and medical, research, and service robotics.