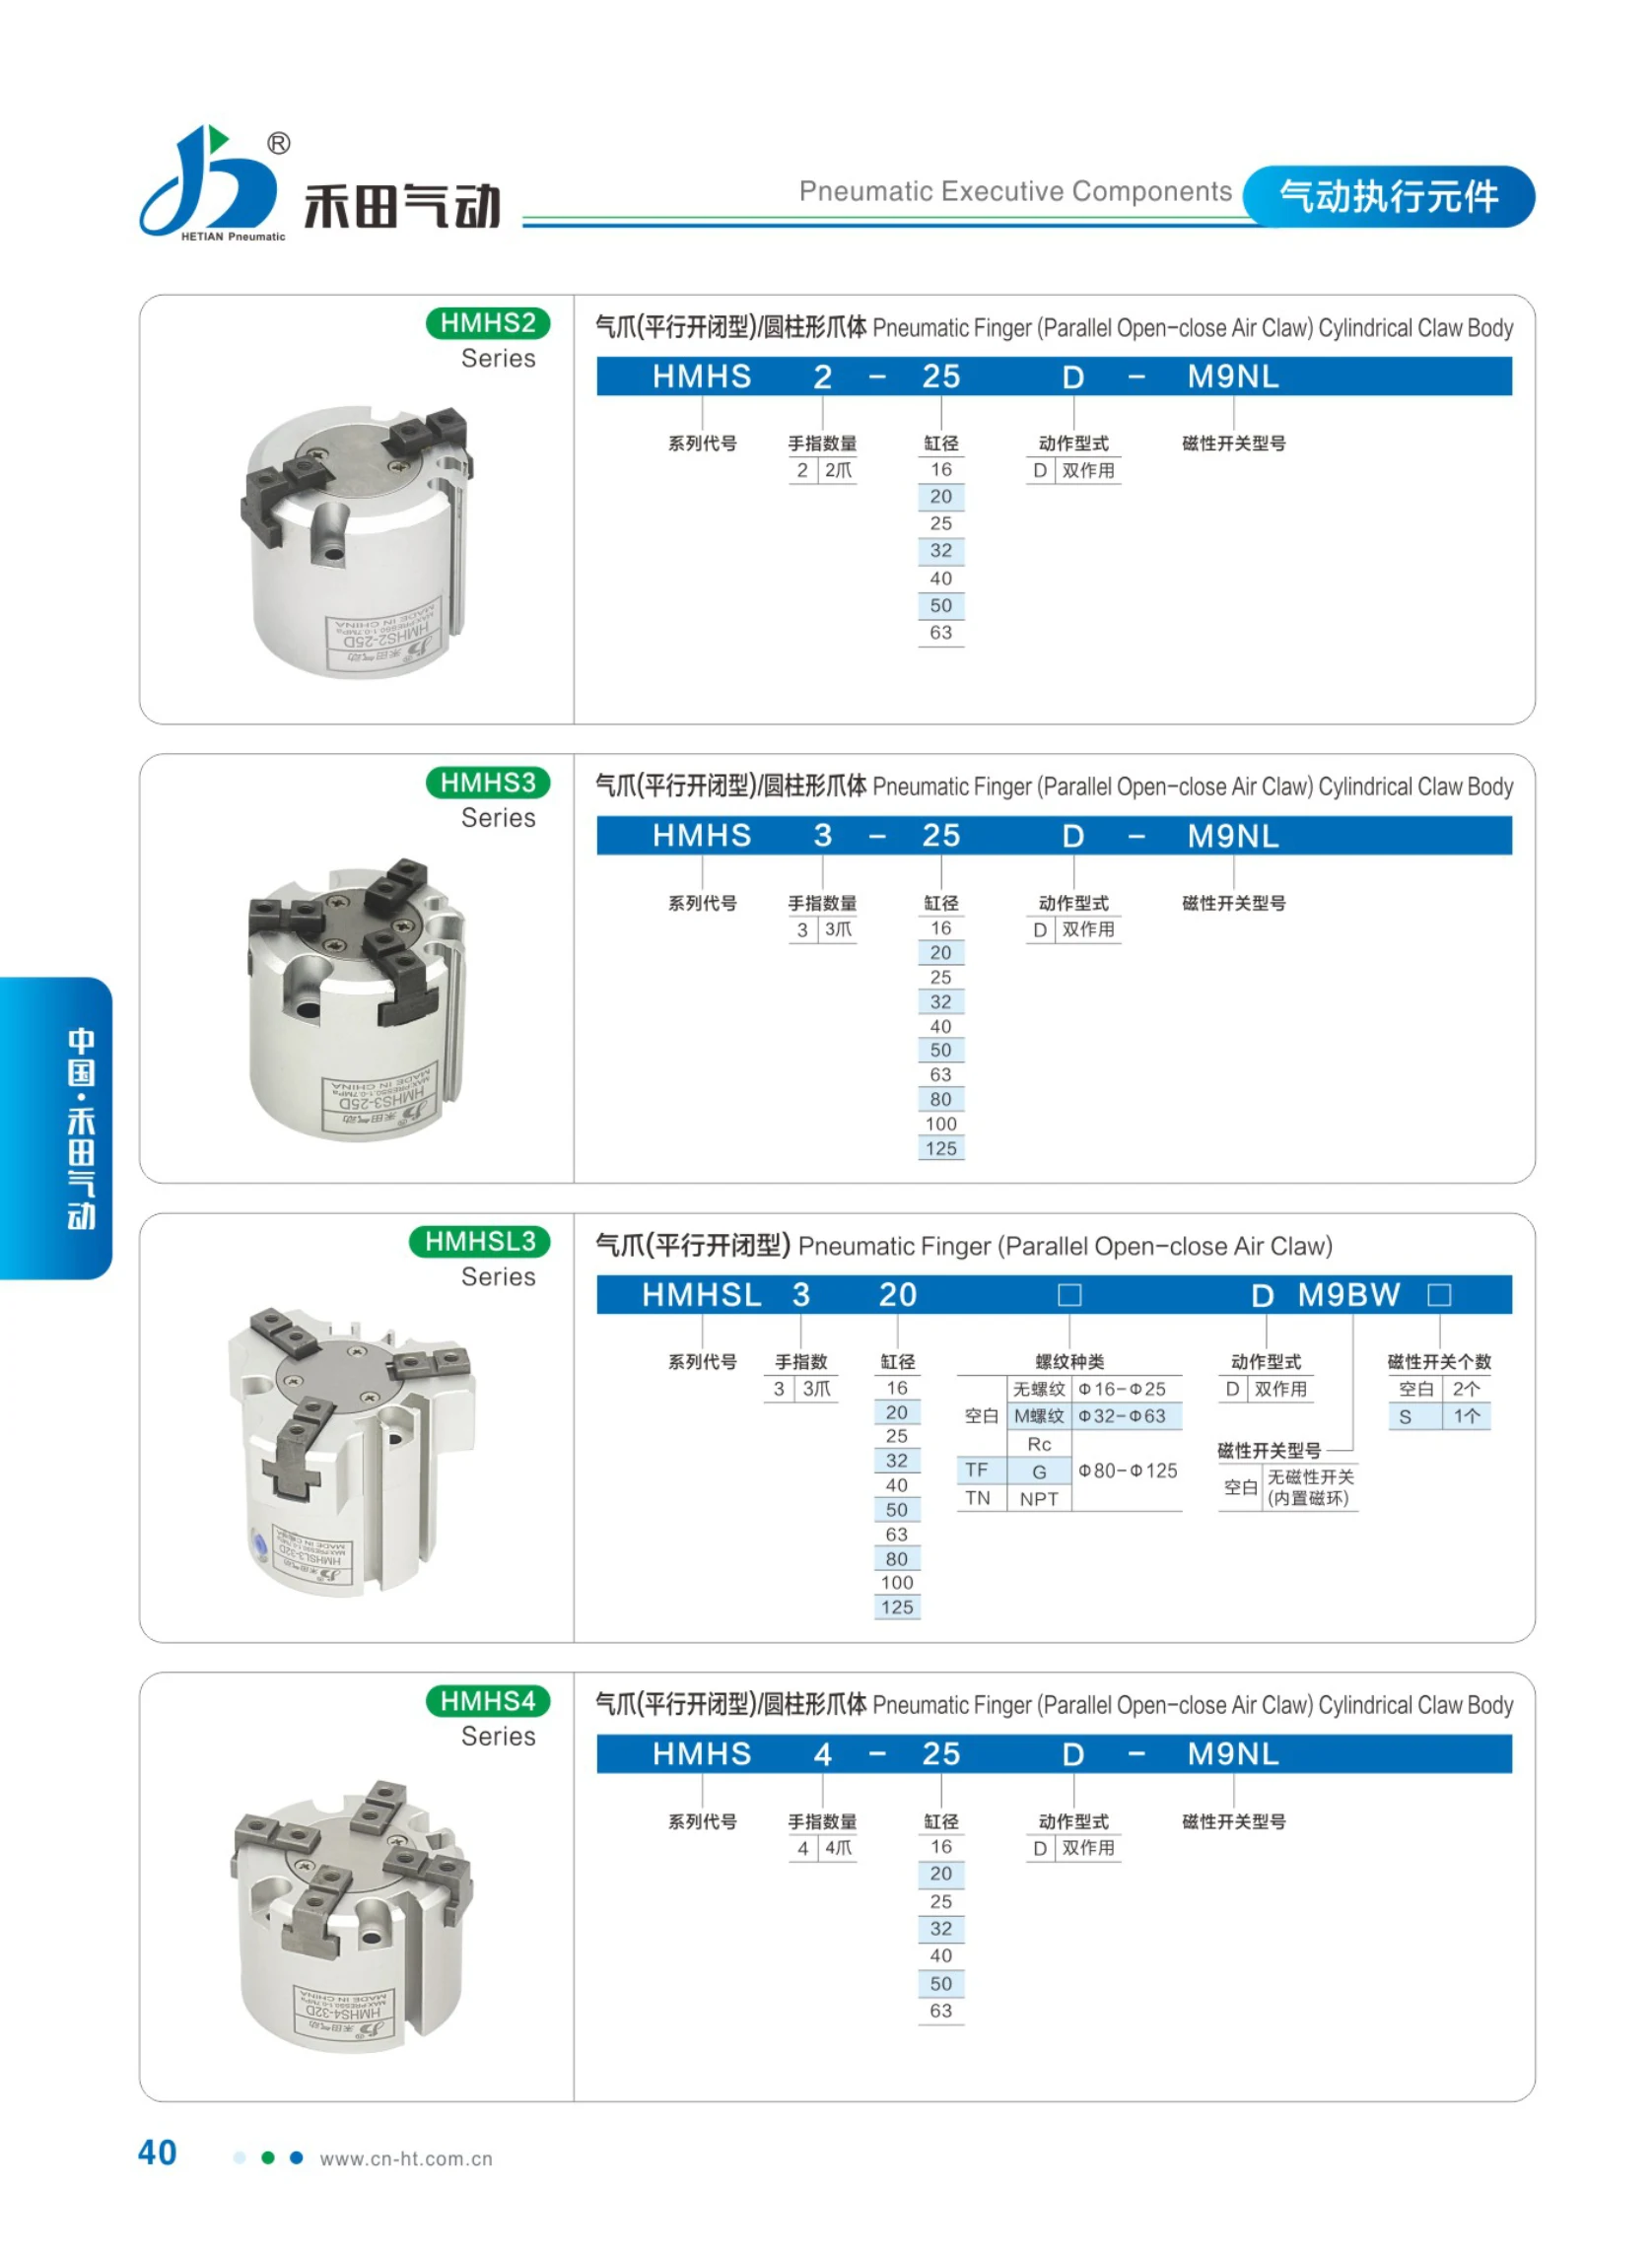
Model · HMS4 Series Pneumatic Gripper (Parallel Opening and Closing)
HMS4 Series Pneumatic Gripper (Parallel Opening and Closing)
The HMS4 series is a parallel-opening pneumatic gripper with a cylindrical body. Its two jaws open and close in parallel along guide rails to pick and place workpieces on automated production lines, either by gripping their outer surfaces or expanding against their inner surfaces. The jaws remain parallel throughout their travel, providing a large contact area and high centering accuracy. This makes the gripper particularly suitable for regularly shaped workpieces, such as square and cylindrical parts. It can be mounted directly on a robot end flange or fixture. The compact cylindrical body is convenient for confined spaces or installations with multiple grippers arranged side by side. The gripper is typically driven by a double-acting cylinder, with gripping force controlled by adjusting the air supply pressure. Magnetic switches can be added to detect fully open and closed positions, and jaws can be selected to suit the workpiece material and shape. This page provides only the series name and configuration (parallel opening and closing / cylindrical body). Refer to the full catalog page for bore sizes, strokes, gripping forces, repeatability, port threads, and model code combination rules.
Overview
The HMS4 series is a parallel-opening pneumatic gripper with a cylindrical body. Its two jaws open and close in parallel along guide rails to pick and place workpieces on automated production lines, either by gripping their outer surfaces or expanding against their inner surfaces. The jaws remain parallel throughout their travel, providing a large contact area and high centering accuracy. This makes the gripper particularly suitable for regularly shaped workpieces, such as square and cylindrical parts. It can be mounted directly on a robot end flange or fixture. The compact cylindrical body is convenient for confined spaces or installations with multiple grippers arranged side by side. The gripper is typically driven by a double-acting cylinder, with gripping force controlled by adjusting the air supply pressure. Magnetic switches can be added to detect fully open and closed positions, and jaws can be selected to suit the workpiece material and shape. This page provides only the series name and configuration (parallel opening and closing / cylindrical body). Refer to the full catalog page for bore sizes, strokes, gripping forces, repeatability, port threads, and model code combination rules.
Product category: Pneumatic components/Pneumatic grippers/Parallel opening and closing
Models & specifications
Models and Specifications
| Model | Name | Specifications |
|---|---|---|
HMS4 | HMS4 Series Pneumatic Gripper (Parallel Opening and Closing, Cylindrical Body) |
Original catalogs